News
Professor Terada presents research at HRI 2025
Professor Kazunori Terada gave a poster presentation at the 2025 ACM/IEEE International Conference on Human-Robot Interaction (HRI 2025), held in Melbourne, Australia.
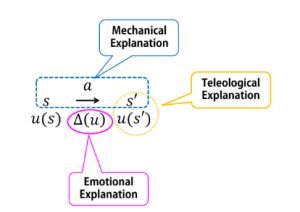
We presented a mathematical framework integrating mechanical explanations based on causal chains, teleological explanations based on goals, and emotional explanations based on changes in utility. The framework supports selecting and combining explanation styles according to the situation and explanatory purpose.
Paper
A Theoretical Integration of Robot Explanations: From Mechanical and Teleological to Emotional Explanations
Kazunori Terada
Proceedings of the 2025 ACM/IEEE International Conference on Human-Robot Interaction (HRI '25), 1675–1679 (2025).